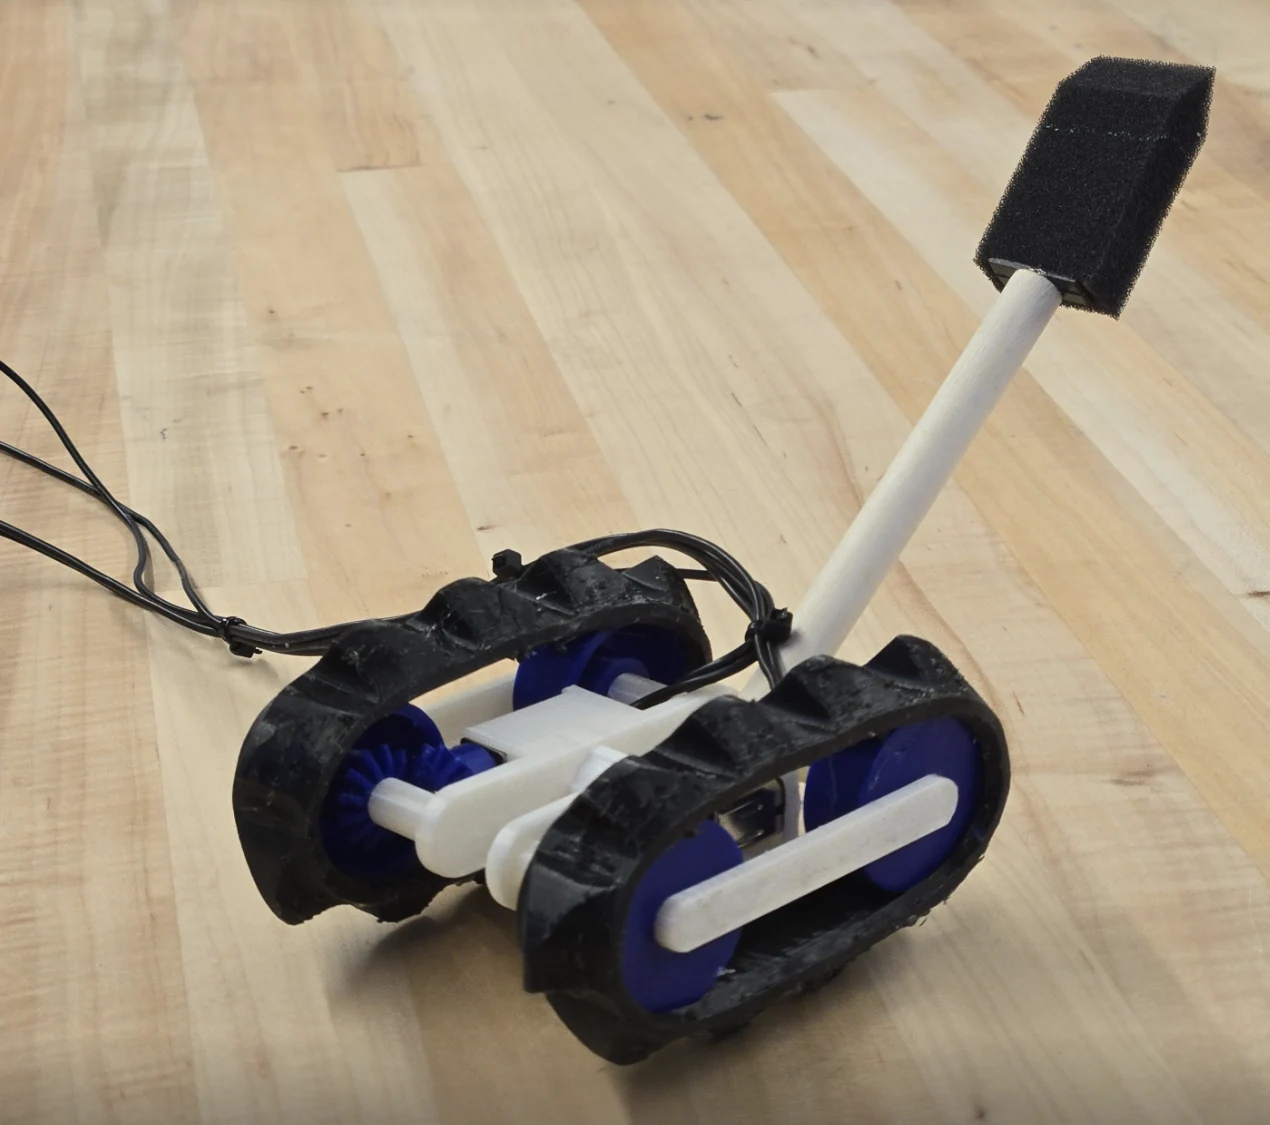
Design alternatives
Achintya Sanjay and I developed a soft robot for a multi-terrain competition with obstacles, slopes, and turns. We explored three concepts: a spring-driven worm, a quadruped using similar compliant legs, and a robot with soft treads.
Comparing the concepts led us to the treaded design for its continuous propulsion, low profile, and adjustable traction and stability.
Tread and chassis design
The final robot used two motor-driven sides connected by a compliant TPE bridge. That connection allowed the sides to respond to uneven terrain, while flexible TPU treads wrapped around the wheels and contacted the ground. A rear tail resisted backward tipping as the robot entered a slope or climbed an obstacle.

We iterated the tread material and printing parameters to improve the part quality. We also tested surface coatings: the silicone trial reduced useful traction, while a flexible glue coating gave better ramp performance.


Obstacle and ramp testing
The report documents an early version tipping at an obstacle of about 5 mm, while the version with the tail could traverse obstacles above 10 mm. The tail normally stayed clear of flat ground and engaged as the chassis pitched upward.
Team contributions
I contributed body CAD and shared the assembly work with Achintya. Our project notes assign fabrication and leg CAD to Achintya. Together we developed and tested the concepts described in the final report. The project received first place in WPI’s 2024 Intercollegiate Soft Robotics Competition.
RBE 530/ME 530 Soft Robot Project Competition.
Alan Pham and Achintya Sanjay, 2024.